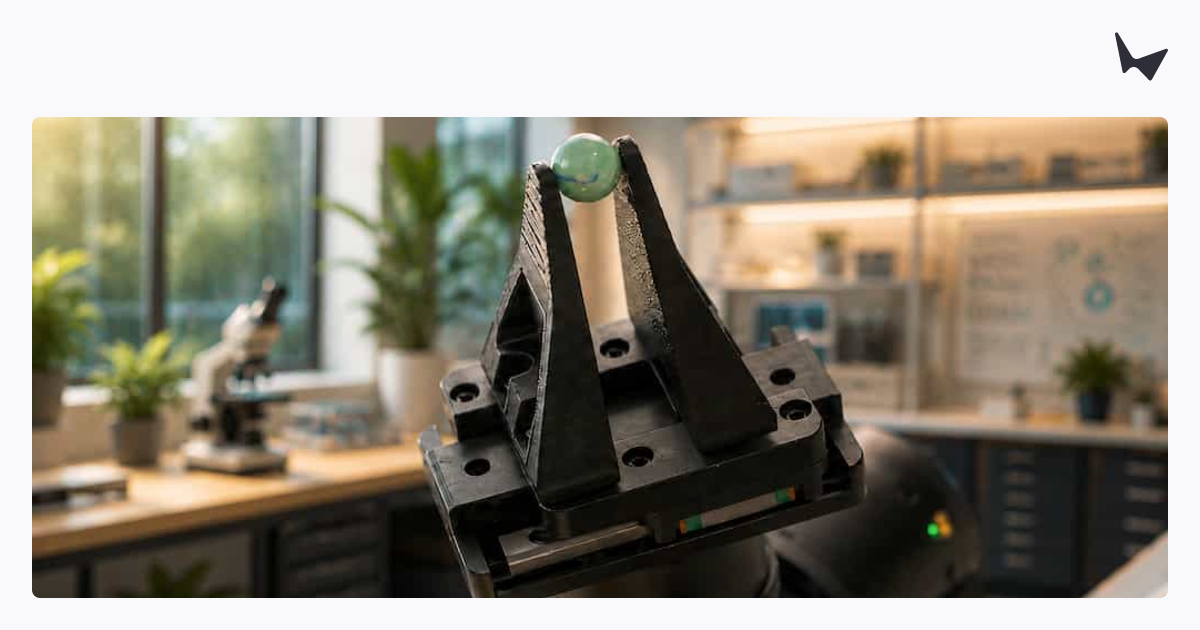
World Labs describes a way to turn a physical robot task into a reusable training environment. Its real-to-sim-to-real account starts by capturing the robot, surroundings, objects and interactions, then reconstructing a simulation that preserves relevant appearance and physical behavior. Developers can vary conditions there, expose a robot's control model to difficult situations and investigate failures before returning to hardware. The company checks reconstructed environments by comparing matching interactions in simulation and reality. That comparison is essential: a simulated world is useful for robot development only if what the robot learns or fails at there carries meaning for the physical task.