Pieter Abbeel is a professor at the University of California, Berkeley, directing its Robot Learning Lab and co-directing BAIR. His research studies how robots learn from demonstrations and experience, alongside work applying AI to robotics and other disciplines.[1]
Start with Apprenticeship learning and reinforcement learning →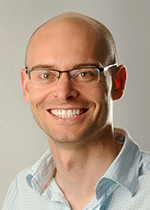
Education

Links
Berkeley faculty pageProfessor · University of California, Berkeley
Leads frontier-model research · Amazon
Career
Research, teaching and deployment
Berkeley identifies Abbeel as Jim Gray Chair in Engineering and describes teaching in introductory AI and advanced learning methods. His companies include Gradescope, Covariant and Berkeley Open Arms. He earned an electrical-engineering MS at KU Leuven in 2000 and a Stanford computer-science PhD in 2008.[1]
Research leadership at Amazon
Amazon’s leadership update says Abbeel will lead its frontier-model research team while continuing robotics work.[3]
Contributions
Learn the task from an expert’s behavior
His dissertation addresses a basic obstacle in robotic control: it can be difficult to write an objective that captures what a skilled person means by performing a task well. Apprenticeship learning uses demonstrations to help infer that objective and construct a controller. The work develops algorithms and performance guarantees under stated assumptions, and evaluates them on the same tasks and environments as the expert.[2]
Connect the learning method with physical control
The dissertation studies unknown and nonlinear dynamics, limited data and the computational difficulty of choosing actions. Its applications include quadruped locomotion and autonomous helicopter aerobatics, developed with collaborators and an expert pilot. These examples connect learning from demonstrations with models and feedback needed to control a physical system; they do not imply unrestricted human-level robotic competence.[2]
Tools, writing & talks
Writing, research & talks
Start here
Apprenticeship learning and reinforcement learningpeople.eecs.berkeley.eduA dissertation linking expert demonstrations, learning algorithms and robotic control.
Read the abstract and introduction for the problem of specifying a robot’s objective, then follow the demonstration-based examples. The mathematical chapters require reinforcement learning, probability and control background.
Author[2]- Amazon leadership updateaboutamazon.com
An employer announcement describing his frontier-model research responsibility.
Subject; employer announcement[3]