How to Train a Cross-Embodiment Robot Navigation Policy with AI Agents
- Source
- developer.nvidia.com
- Author
- Tanya Lenz
- Date
Context
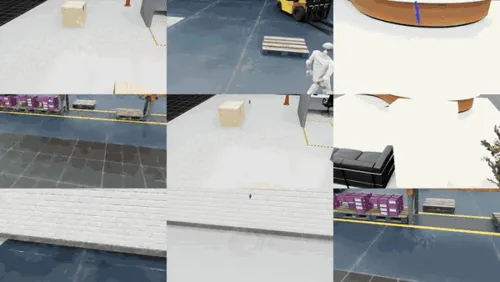
NVIDIA's COMPASS workflow adapts an existing robot-navigation policy by training a specialist that corrects its actions for a selected robot and environment. A coding coordinates development tasks such as preparing a simulated scene, running initial checks and comparing trained checkpoints. The tutorial keeps human approval at key stages, including accepting the scene and promoting a checkpoint.
The comparison uses matched starting conditions and goals to assess whether the specialist improves on the base policy. At runtime, the trained navigation policy controls motion; the coding agent's role is development and validation. The tutorial ends at checkpoint , with physical deployment requiring separate checks for the target robot.
- AI agent — An AI system that doesn't just answer once but works toward a goal in a loop — taking actions, reading the results, and deciding what to do next.
- eval — A repeatable test for AI quality — a set of tasks plus scoring — used the way software teams use test suites, because model output is too variable to judge by eyeballing.
 articleScaling NVIDIA TensorRT Performance Optimization Beyond a Single Build Route with the Global Performance Tuner, Part 2
 articleAccelerating Mamba-2 with High-Performance Forward Pass Kernels in NVIDIA CUDA Tile
 articleScale Agentic Coding Workflows with Meta’s Muse Spark Open on NVIDIA GB300 NVL72
 articleOptimizing Agent Reliability and Tool Calling Efficiency for Chip Design Using NVIDIA NeMo Gym
Checking sign-in…
Loading comments…