Post-Train NVIDIA Cosmos 3 Edge for On-Device Robot Control
Source
developer.nvidia.com
Author
Michelle Horton
Date
Context
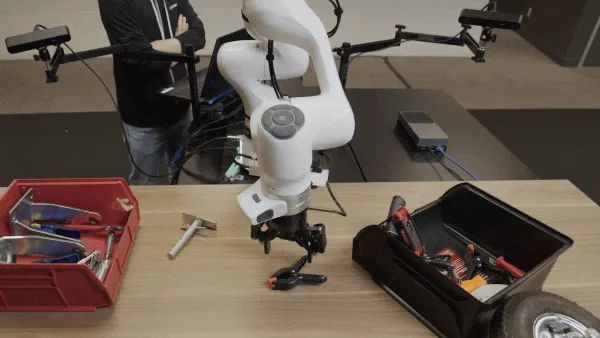
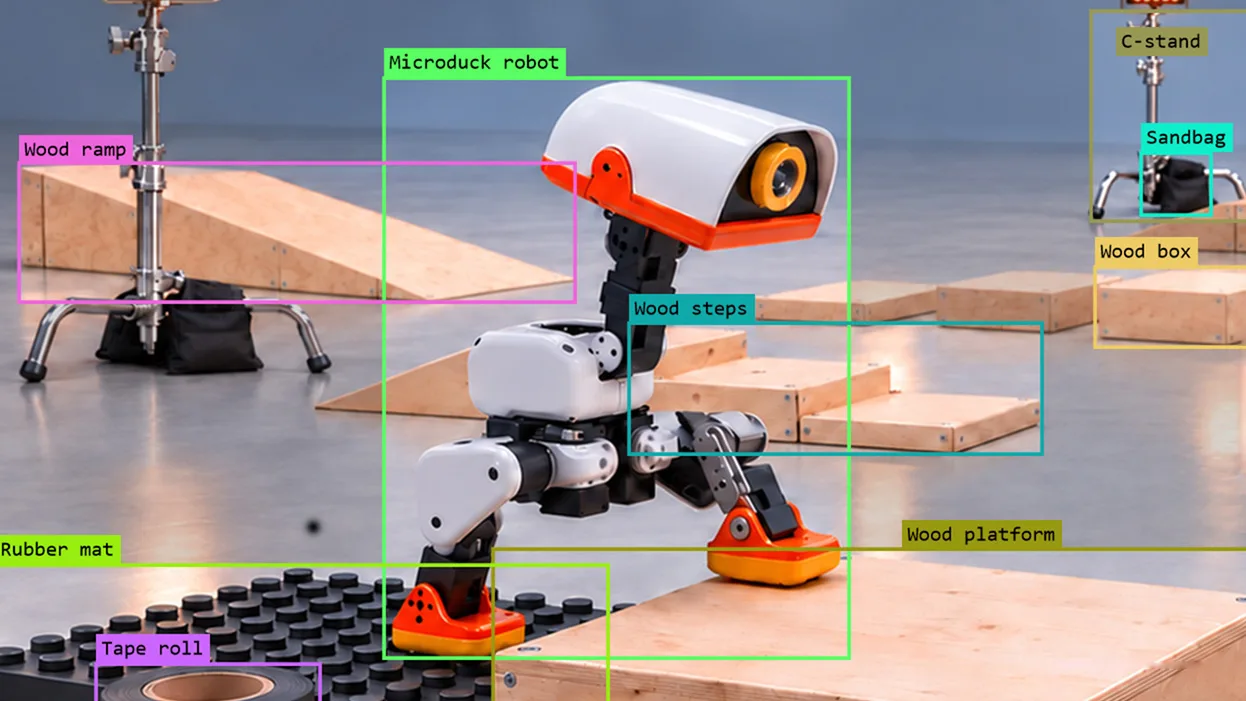
NVIDIA's Cosmos 3 Edge tutorial describes a robot policy that takes camera views and measured robot state and returns a sequence of actions on onboard hardware. In the reported Jetson Thor configuration, generating 32 actions takes about 1.53 seconds; executing that sequence at 15 actions per second covers about 2.13 seconds.
The 15 Hz figure therefore describes action execution, not 15 fresh model decisions each second. The model replans in chunks. The tutorial separately reports 22.9% success in its RoboLab simulation evalA repeatable test for AI quality — a set of tasks plus scoring — used the way software teams use test suites, because model output is too variable to judge by eyeballing.Full definition →, providing a task-performance measure alongside the onboard inferenceRunning a trained model to get answers — the phase where AI is actually used, as opposed to trained.Full definition → timing.
Terms in this piece · Glossary
eval — A repeatable test for AI quality — a set of tasks plus scoring — used the way software teams use test suites, because model output is too variable to judge by eyeballing.
inference — Running a trained model to get answers — the phase where AI is actually used, as opposed to trained.